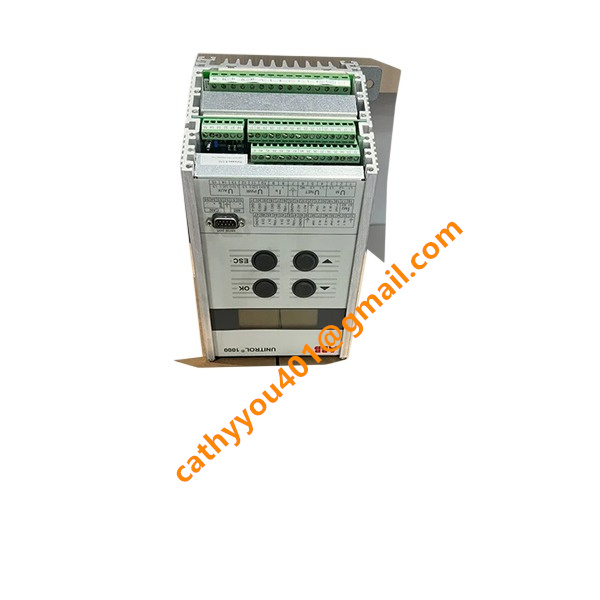








Description
-
BrandABB
-
Model3HAC17484-3/06
-
Product NameAC Servo Motor with Pinion Gear for Industrial Robot
-
Place of OriginSweden
-
Customs HS Code85015200
-
Power Supply230 VAC
-
Dimensions238 mm × 134 mm × 120 mm
-
Weight6.4 kg
-
Operating Temperature-10℃ to +55℃
-
Storage Temperature-40℃ to +85℃
-
Warranty12 month
-
Product Statusnew
ABB 3HAC17484-3/06 Servo Motor Characteristics (IRB7600 Robot Axis Motor)
Motor Type: Permanent-magnet AC servo motor designed for heavy-duty axis operation of IRB7600 industrial robot
Hardware Revision: 06
Integrated Component: Internal electromagnetic holding brake
Encoder System: High-precision serial absolute encoder equipped with backup battery interface to preserve position data during power failure
Temperature Sensing: Embedded PT100/PTC thermal sensor provides over-temperature protection for motor windings
Interfaces: Independent power connector and encoder signal connector; without user-accessible digital or analog I/O channels
Mechanical Feature: Output shaft fitted with pinion for direct connection to robot gearbox
Protection Class: IP65 for motor main housing when cable glands are properly mounted
Operating Ambient Temperature: -10 °C ~ +50 °C
Cooling Method: Passive natural convection cooling
Compatibility: Works in conjunction with IRC5 robot drive system; exclusively used for designated axes of IRB7600 manipulator
Mechanical Property: High torque density and rugged housing, suitable for heavy-duty cyclic industrial working conditions
Signal Description: Motor power phases U/V/W, PE protective earth, brake control wires BR+/BR; differential serial encoder signals, +5V encoder power supply, digital ground, battery backup terminals, and shield connected to motor housing
Remarks: All power and feedback signals are wired to the robot internal drive unit. Axis fine calibration and revolution-counter reset must be completed after motor replacement.

Parameter-Setting Procedure for ABB 3HAC17484-3/06 Servo Motor (IRB7600, IRC5 Controller)
General Note
No adjustable on-board parameters are stored within this robot servo motor. All motor-associated parameters reside in the IRC5 controller system files. Genuine ABB replacement motors do not require manual entry of nameplate information.
Pre-Setting Preparation
Finish mechanical assembly and complete all electrical connections for the 3HAC17484-3/06 motor.
Inspect power cables and encoder wiring harnesses for short-circuits, open-circuits and damaged pins.
Mechanically lock the robot unit and ensure all personnel stay clear of the robot operating envelope.
Power up the IRC5 controller and establish connection with the FlexPendant.
Restore the original robot system backup file if it is available.
System Parameter Verification
Launch Configuration Editor via FlexPendant or RobotStudio.
Access the Motion-Motor section and validate that the target axis is configured with the correct motor profile for 3HAC17484-3/06.
Inspect drive unit assignment to ensure the physical drive channel corresponds to the matched robot axis.
Retain factory preset values for rated current, peak current, thermal threshold and brake settings; arbitrary modification is prohibited.
Cross-check mechanical unit parameters including gear ratio, axis rotation direction, positive and negative software travel limits against the original IRB7600 factory configuration.
Revolution Counter Update
Manually jog the target axis to its mechanical zero reference position.
On FlexPendant: Menu → Calibration → Revolution Counter.
Choose the axis equipped with 3HAC17484-3/06 and trigger Update Revolution Counter.
Acknowledge the completion pop-up notification.
Axis Fine Calibration
Proceed to the Calibration menu and start Fine Calibration for this axis.
Strictly comply with on-screen instructions; refrain from external manual intervention while calibration is in progress.
Upon successful fine calibration, the controller automatically updates axis offset values and position-loop tuning parameters.
Brake Parameter Check & Functional Test
Initiate the brake test from the FlexPendant service menu.
Validate proper brake engagement and disengagement without brake-related fault messages.
When a brake alarm occurs, inspect BR+/BR- wiring connections and the 24 V brake power supply.
Motion Tuning Verification
Jog the axis at low speed, monitor real-time motor current, mechanical vibration and operating noise.
Maintain default servo gain settings; gain adjustment shall only be performed under instruction from an ABB qualified service engineer when noticeable oscillation arises.
Carry out full-stroke motion test, ensure no alarms for overtemperature, encoder communication failure or position deviation.
Post-Setting Backup
Make certain no motor-relevant error entries exist in system logs.
Create a complete fresh system backup to preserve the latest calibrated data.

GDB021BE
Unitrol 1020
698B275U01
SM810K01
BC810K02
PP886
PBA800
RED615


.jpg)